Tianxin Hu is a Research Assistant at the Centre for Advanced Robotics Technology Innovation (CARTIN), Nanyang Technological University (NTU), in Prof. Lihua Xie’s group, working on reinforcement learning for humanoid locomotion. He received the M.Sc. degree in Computer Control and Automation from NTU in 2026. His research interests include optimization-based planning and control, reinforcement learning for legged locomotion, and integrating structured dynamical priors into learning-based control.
Education
- M.Sc., Computer Control and Automation, Nanyang Technological University (NTU), Singapore, Aug. 2024 - Jan. 2026
- B.Eng., Vehicle Engineering, Wuhan University of Science and Technology (WUST), China, Sep. 2020 - Jun. 2024
Experience
- Research Assistant, Centre for Advanced Robotics Technology Innovation (CARTIN), Nanyang Technological University (NTU), Singapore, Jun. 2026 - Present
Awards
- ICRA 2026 Workshop Best Poster Award
Other Information
- Work Email: tianxin.hu@ntu.edu.sg
Publications
First-Author Publications
-
Energy-Constrained Navigation for Planetary Rovers with Singular Internal Power Source.International Conference on Control and Automation (ICCA), 2026.
-
Swept volume-aware trajectory planning and MPC tracking for multi-axle swerve-drive AMRs.IEEE International Conference on Robotics and Automation (ICRA), pp. 14505–14512, 2025.
-
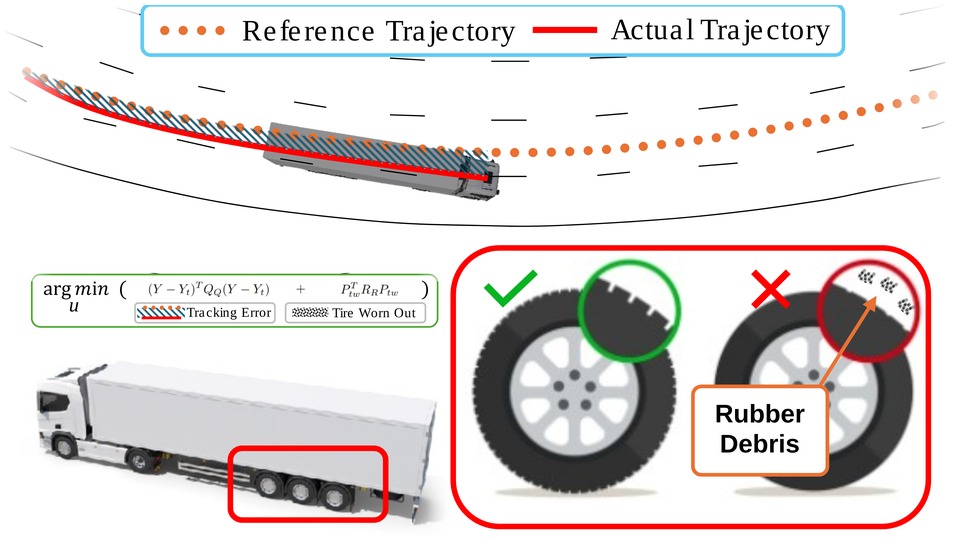 Tire wear aware trajectory tracking control for multi-axle swerve-drive autonomous mobile robots.Journal of Automation and Intelligence, vol. 4, no. 4, pp. 243–253, 2025.
Collaborative Publications
-
Interactive Object Tracking on Gait-Parameterized Locomotion Policy.International Conference on Control, Automation, Robotics and Vision (ICARCV), 2026.
-
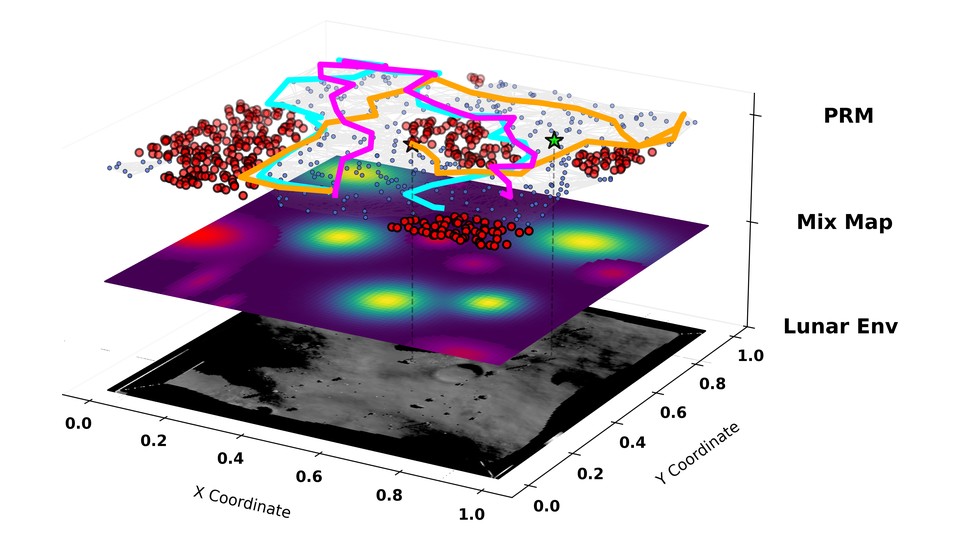 Multi-Agent Off-World Exploration for Sparse Evidence Discovery via Gaussian Belief Mapping and Dual-Domain Coverage.IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026.
-
TGSFormer: Scalable temporal Gaussian splatting for embodied semantic scene completion.IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), pp. 11881–11890, 2026.