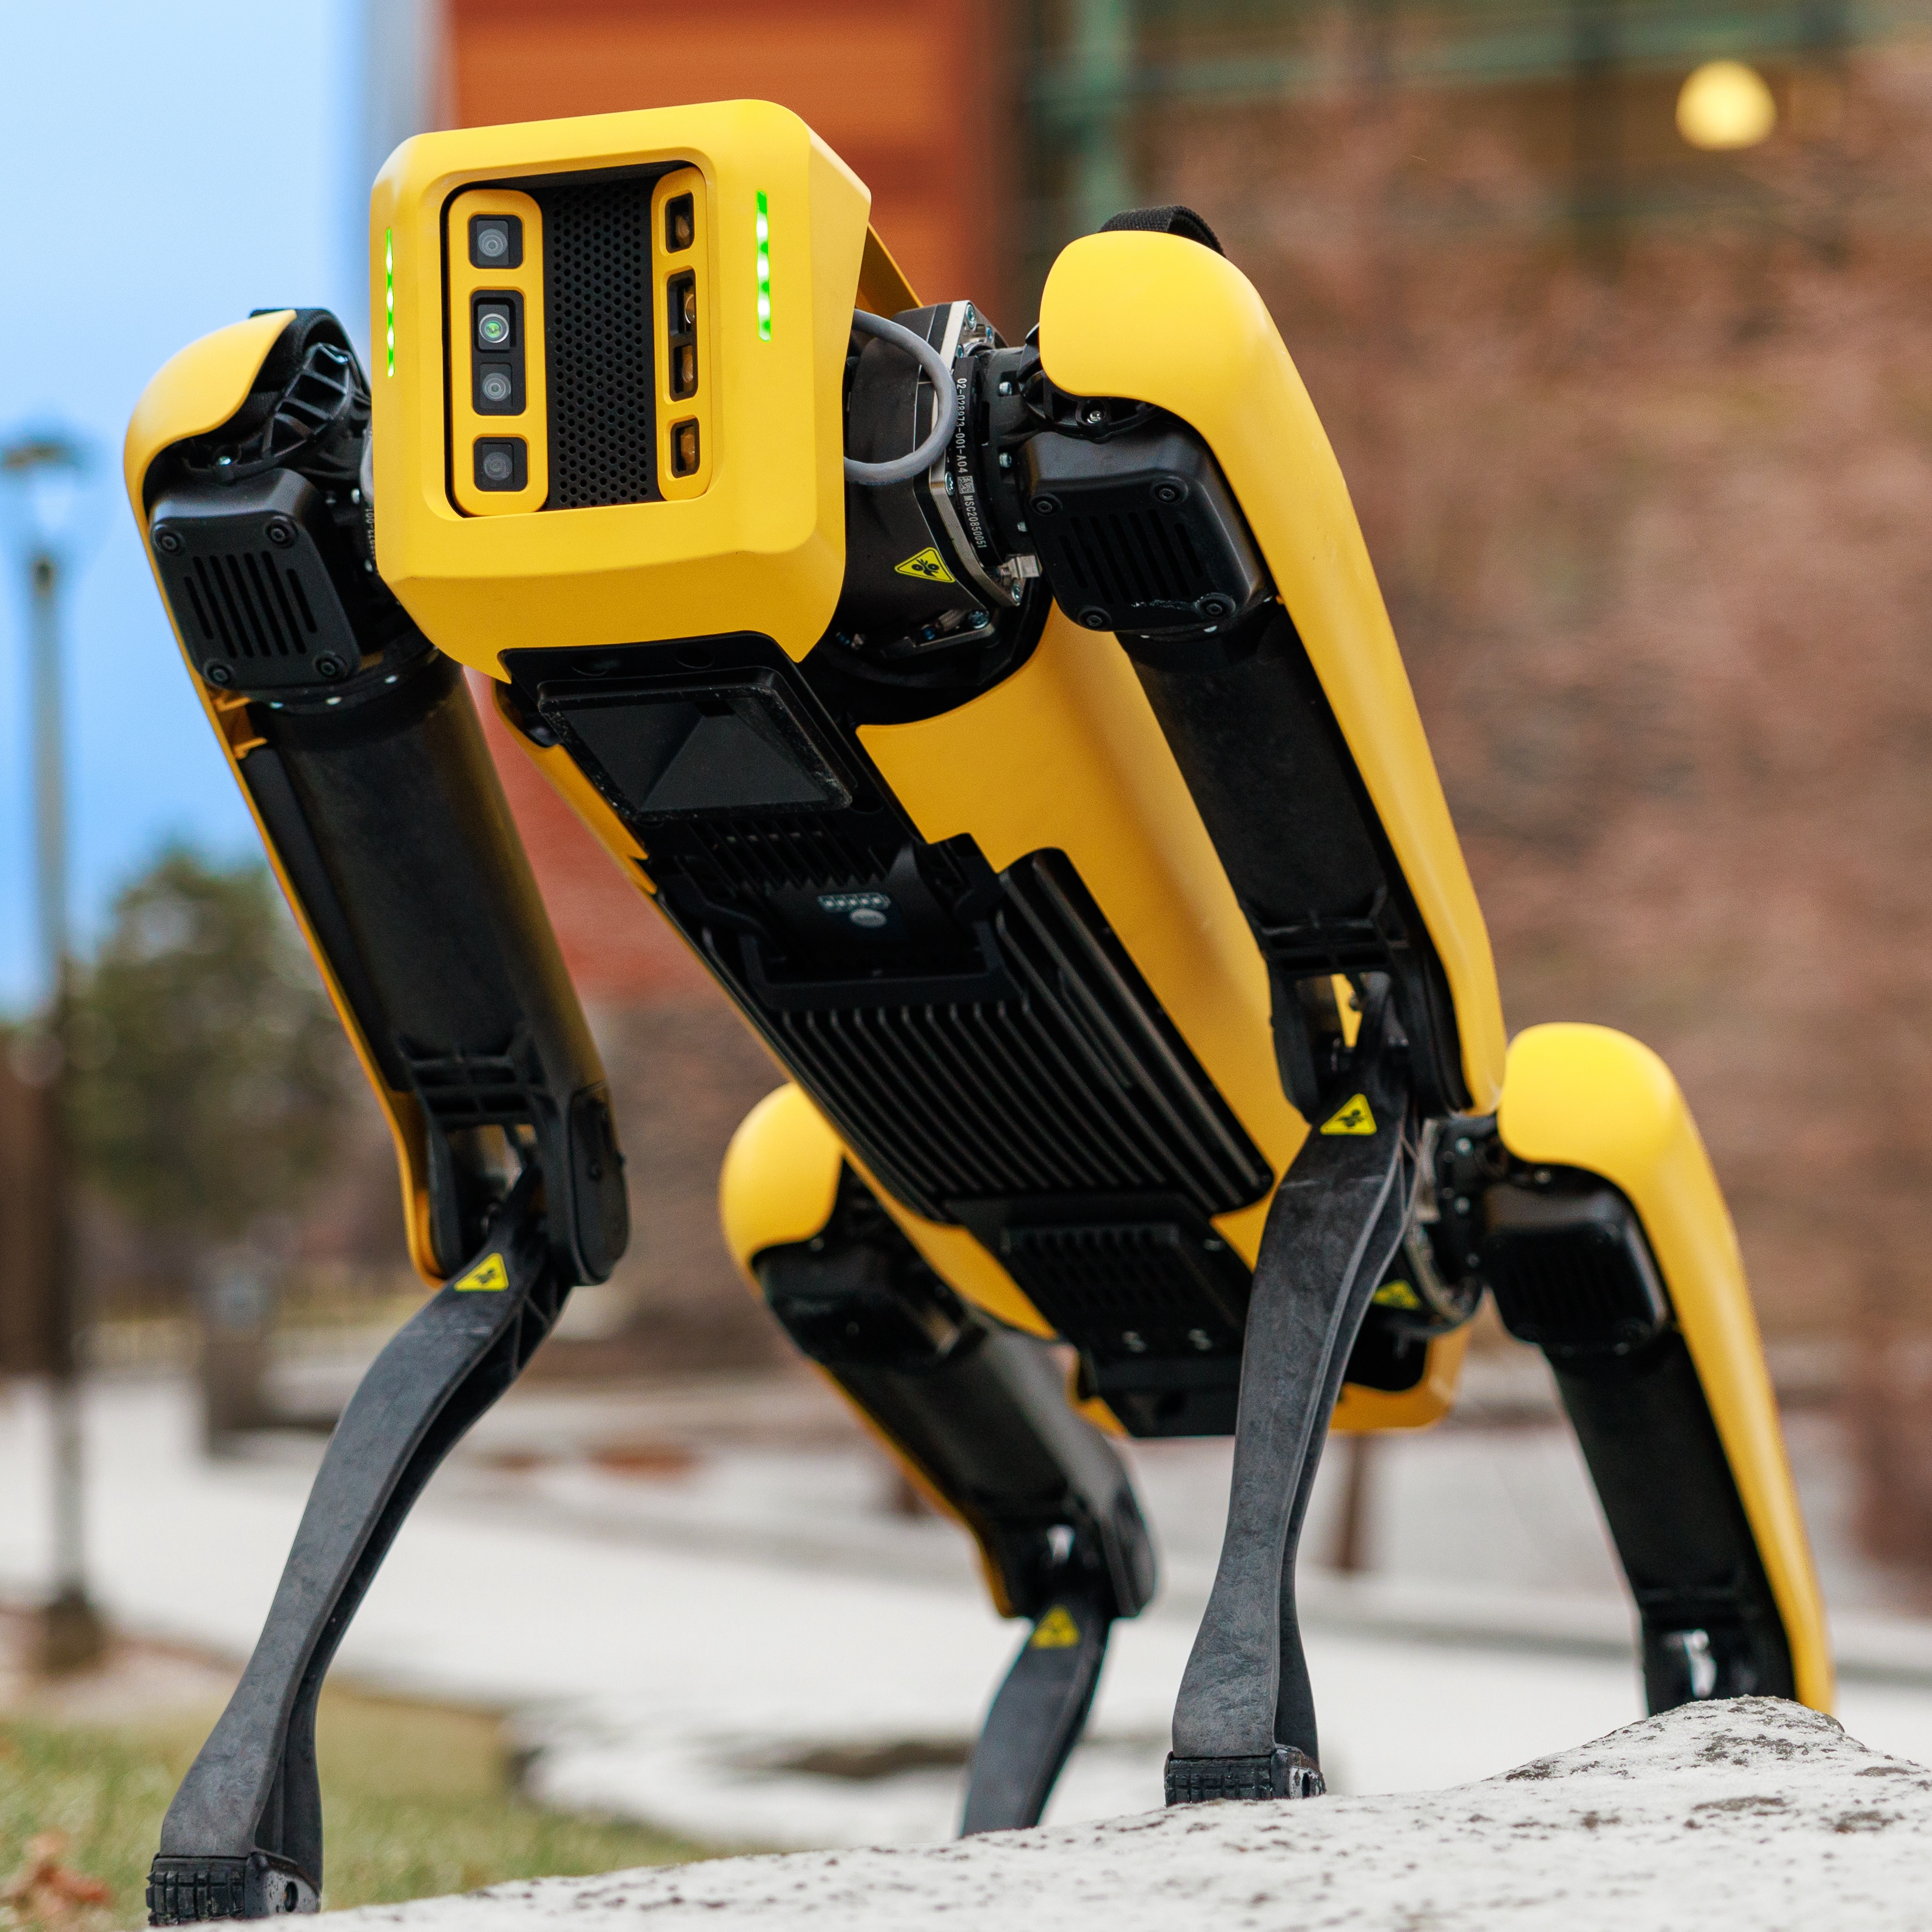
Spot is a quadruped robot provided by DARPA, serving as a core experimental platform for SAIR Lab’s research on real-world Spatial AI under mission-driven constraints. Rather than a lab-only system, Spot anchors our work in challenge-scale environments where robustness, repeatability, and recovery matter.
It is the platform where our methods are evaluated end-to-end: from perception and memory to planning and execution, across repeated deployments in the same evolving spaces.
Publications
-
Point-Level Refinable Semantic Mapping for Spatial Understanding.arXiv preprint arXiv:2610.31476, 2026.
-
Neuro-Symbolic Learning for Long-Horizon Task Planning Under Complex Logical Constraints.arXiv preprint arXiv:2606.06877, 2026.